Product Overview
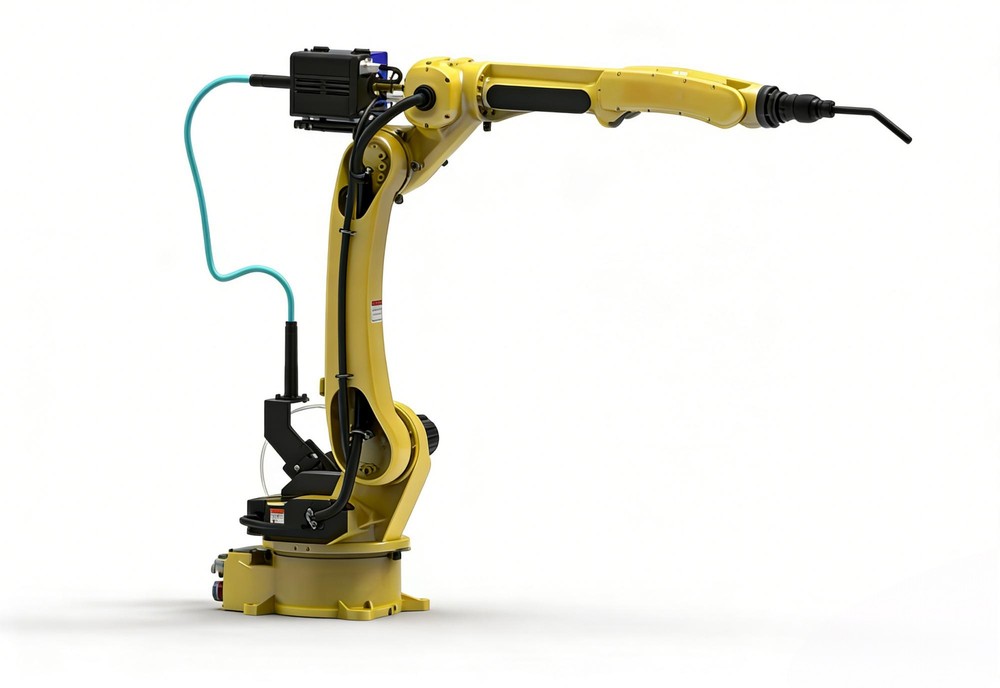
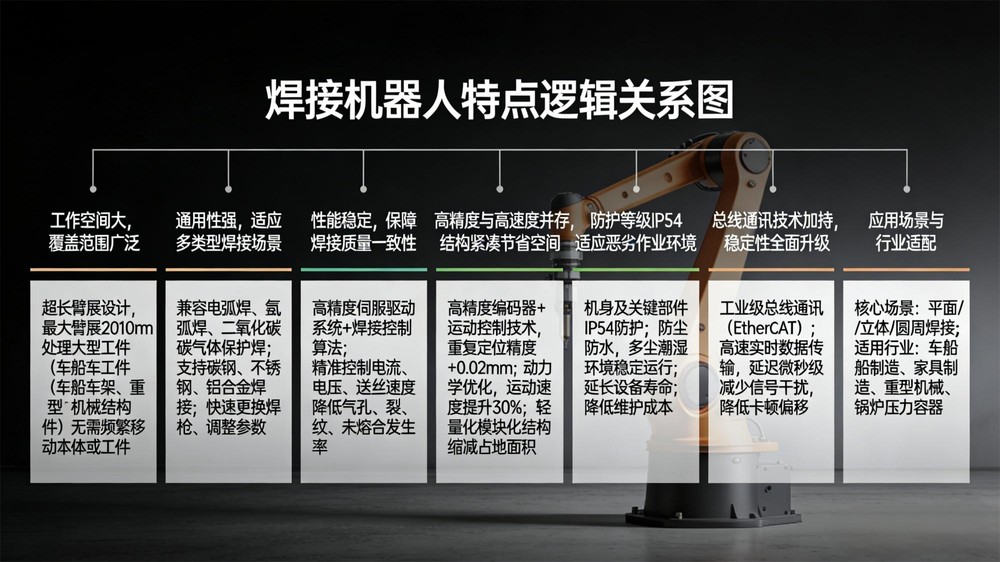
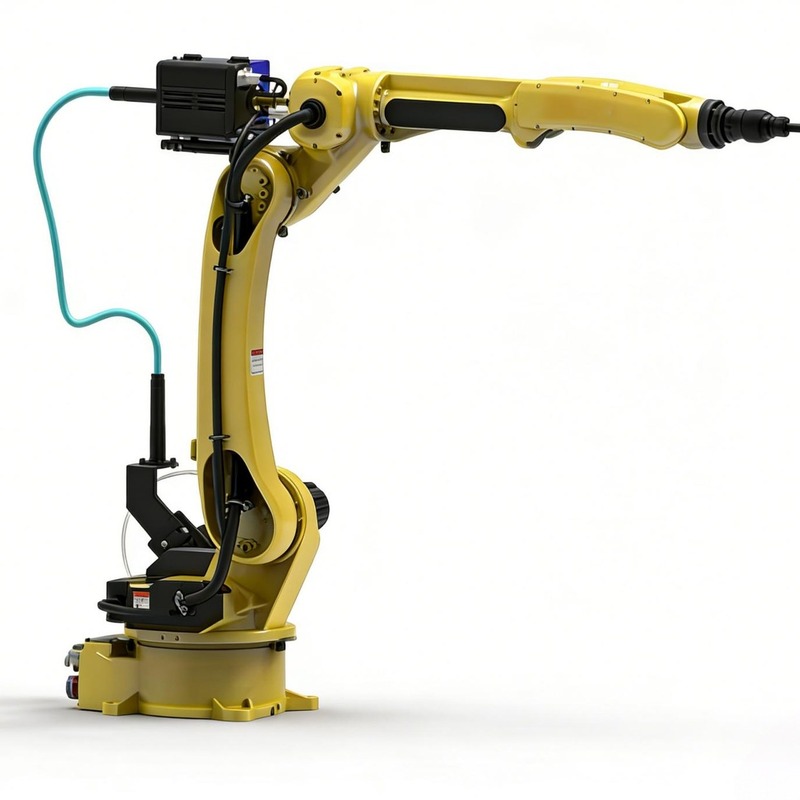
The Welding Robot features an ultra-long arm design with a maximum reach of 2010 mm, compatible with arc welding, argon arc welding, and CO₂ gas-shielded welding. Employing a high-precision servo drive system and advanced welding control algorithms, it achieves a repeat positioning precision of ±0.02 mm with an IP54 protection rating, delivering high-speed, high-quality automated welding.
Product Description
Automated welding is one of the most economically impactful applications of industrial robotics, delivering consistent weld quality, higher productivity, and reduced labor costs compared to manual welding. The Welding Robot is engineered specifically for this application, with design choices optimized for the unique demands of arc-based welding processes rather than being a general-purpose robot adapted for welding duty.
The robot's 2010 mm maximum arm reach provides an exceptionally large working radius, enabling it to weld large workpieces — such as structural steel sections, pressure vessel components, and vehicle frames — without repositioning. This extended reach reduces the need for workpiece positioning systems and minimizes non-productive motion time, directly increasing welding throughput. The robot's vertical-joint 6-DOF (degree of freedom) configuration provides the dexterity required for complex three-dimensional weld paths, including circumferential, multi-pass, and positional welds.
Compatibility with multiple welding processes — arc welding, argon arc welding (TIG), and CO₂ gas-shielded welding (MAG/MIG) — makes the robot a versatile platform adaptable to diverse material and quality requirements. The high-precision servo drive system ensures that the welding torch maintains the exact travel speed and angle specified by the welding procedure, eliminating the speed variation and torch-angle inconsistency that are the primary causes of weld defects in manual welding. The repeat positioning precision of ±0.05 mm (with the system design supporting ±0.02 mm capability) ensures that every weld start point, end point, and intermediate position is executed with exacting repeatability.
The robot achieves a 30%+ improvement in motion speed compared to conventional welding robots, translating directly into higher welding throughput. The EtherCAT bus communication technology provides microsecond-level data transmission latency, enabling the robot controller, servo drives, and welding power source to communicate in real time — a critical capability for synchronized control of torch position and welding parameters during dynamic weld paths.
The IP54 protection rating ensures reliable operation in the harsh welding environment, where welding spatter, metal dust, and humidity are ever-present. The robot is rated for operation at 0–45 °C and 20–80% RH (non-condensing), and supports both floor-mounted and inverted (ceiling-suspended) installation for maximum layout flexibility. The J1 axis range is ±180° with a maximum speed of 175°/s, and the J6 axis range is ±360° with a maximum speed of 260°/s, providing the speed and reach required for high-productivity welding cells.
Key Features
- Ultra-long arm reach of 2010 mm for large workpiece welding
- Multi-process compatibility: arc, argon arc (TIG), CO₂ gas-shielded welding
- High-precision servo drive system for consistent weld quality
- Repeat positioning precision ±0.05 mm, motion speed improved 30%+
- IP54 protection for spatter, dust, and humidity resistance
- EtherCAT bus communication with microsecond-level latency
- Compact structure, floor or ceiling installation
Technical Specifications
| Parameter | Value |
|---|
| Type | Vertical joint, 6 DOF |
| Effective Payload | 12 kg |
| Working Radius | 2010 mm |
| Repeat Positioning Precision | ±0.05 mm |
| Robot Weight | 180 kg |
| Power Capacity | 2.0 KVA |
| Protection Rating | IP54 |
| Operating Environment | 0–45 °C, 20–80% RH (non-condensing) |
| Installation | Floor or ceiling mount |
| J1 Range / Max Speed | ±180° / 175°/s |
| J6 Range / Max Speed | ±360° / 260°/s |
| Primary Application | Welding |
Applications
Metal structure welding (flat, vertical, circumferential); vehicle and ship manufacturing, furniture manufacturing, heavy machinery, boiler and pressure vessel fabrication, and other manufacturing sectors.
![]()
![]()
![]()