Product Overview
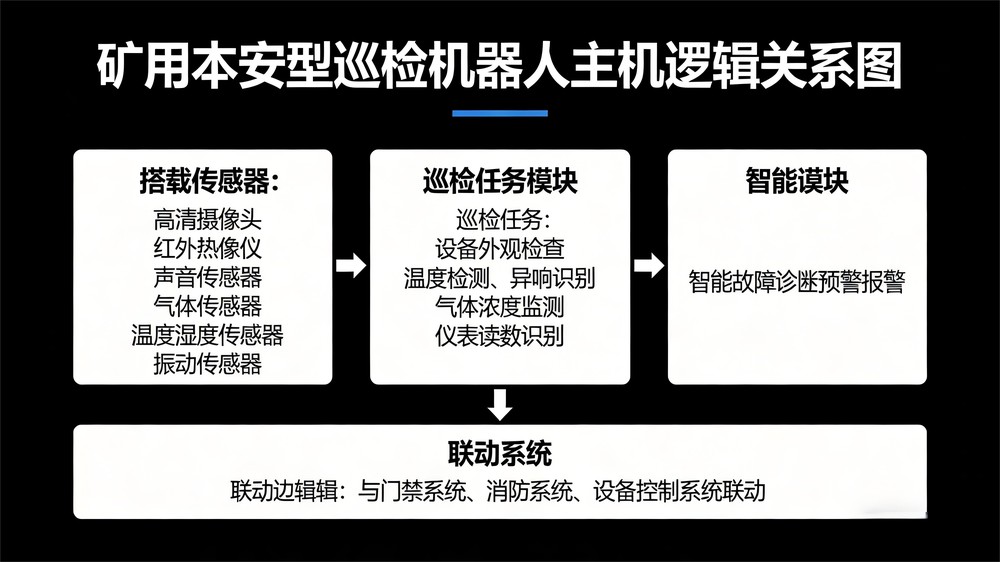
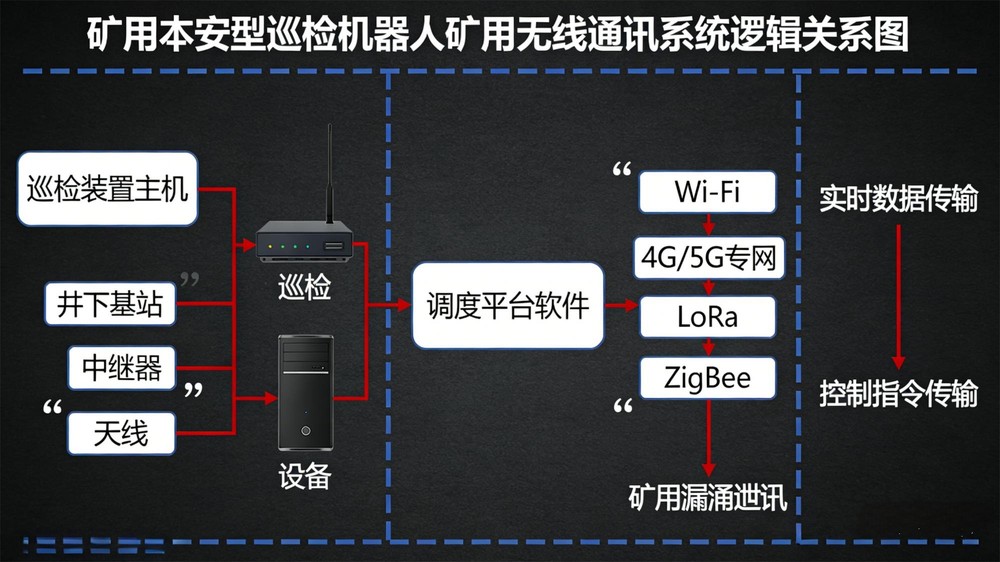
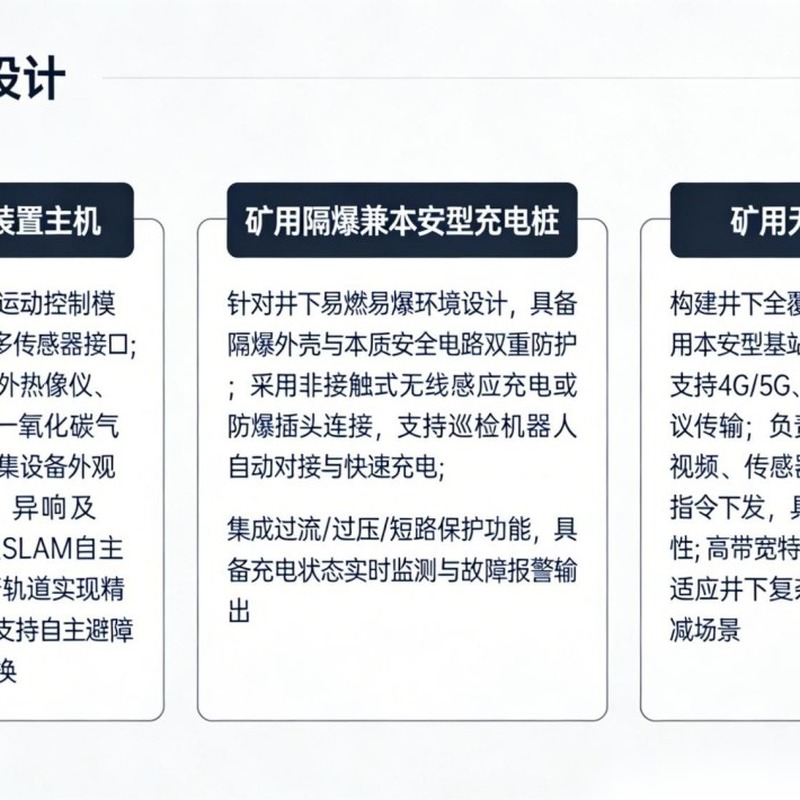
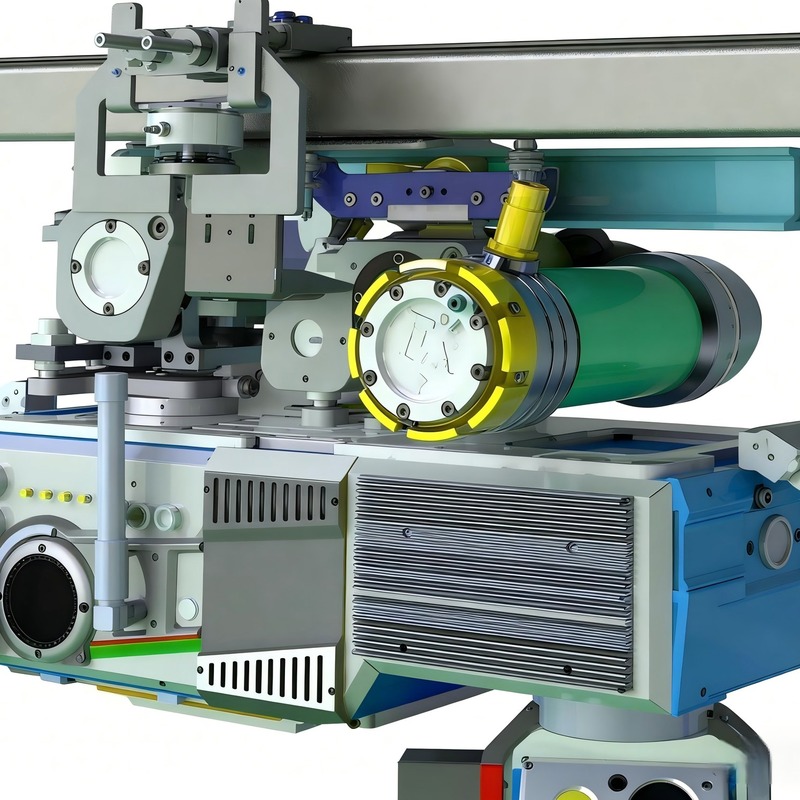
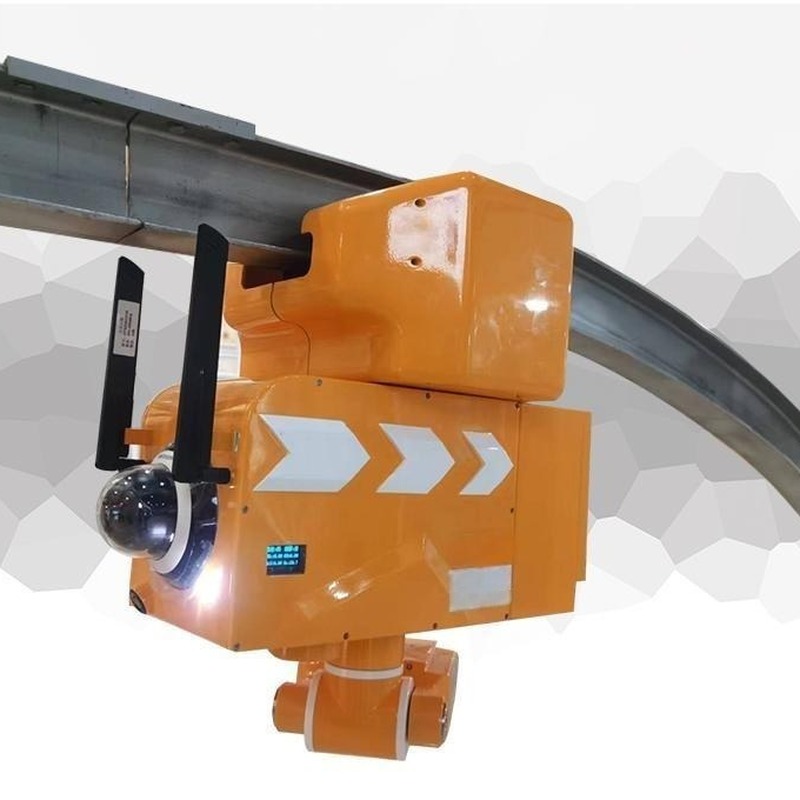
The Mining Intrinsically Safe Inspection Robot comprises an inspection host, flameproof-and-IS charging pile, wireless communication system, dispatch platform software, and running rail. Equipped with multiple sensors, it performs all-weather inspection and monitoring of station equipment — replacing manual labor for inspection, detection, monitoring, fault diagnosis, and early warning.
Product Description
Routine inspection of critical mine infrastructure — substations, pump rooms, belt conveyor lines, and ventilation machine rooms — is traditionally performed by human workers walking predefined routes, visually checking equipment, and manually recording readings. This approach is labor-intensive, inconsistent, and exposes personnel to hazardous environments. The Mining Intrinsically Safe Inspection Robot eliminates these limitations by performing automated, sensor-rich, continuous inspection with consistent thoroughness.
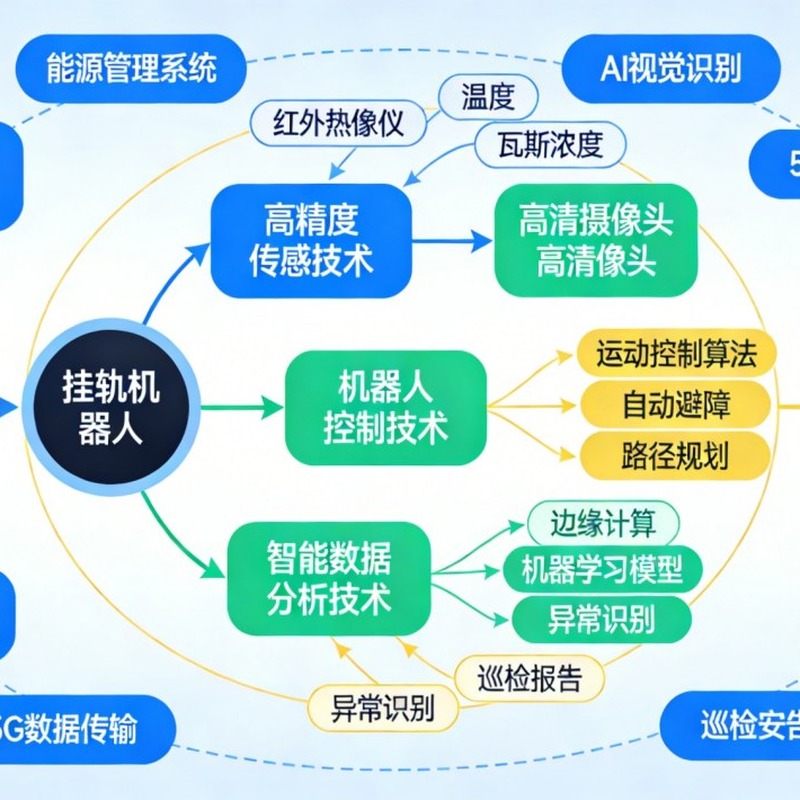
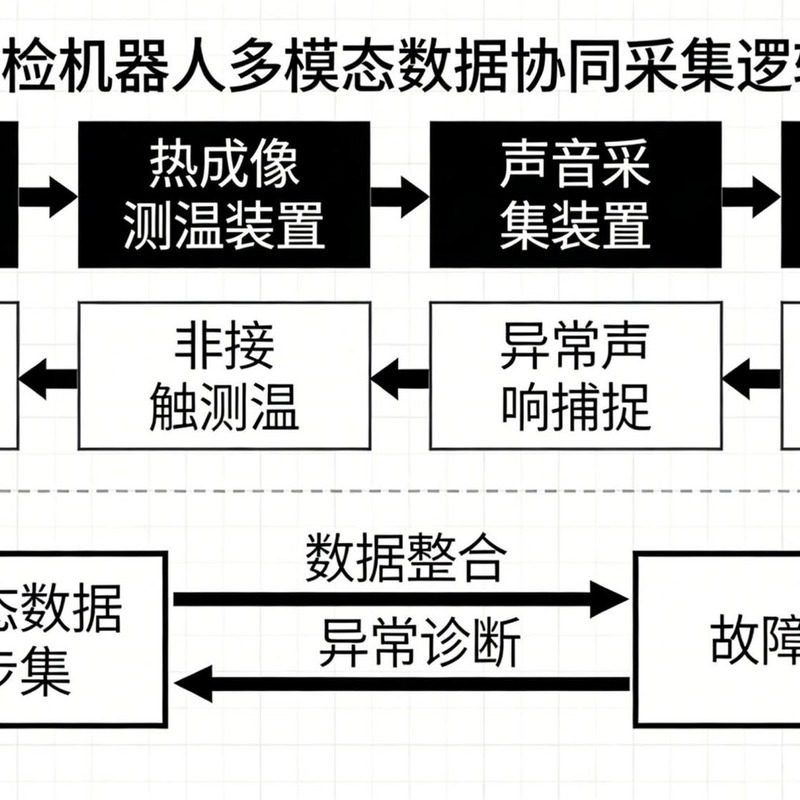
The robot's multi-sensor payload is its defining capability. A high-definition camera (4 megapixels, 16× digital zoom, 1080p@60fps) provides detailed visual inspection of equipment conditions, connections, and indicators. An infrared thermal imager (384×288, ±2°C or ±2% accuracy, thermal sensitivity 0.08 K, range −20 °C to 150 °C) detects thermal anomalies in electrical connections, bearings, and motor housings — identifying developing faults invisible to the human eye. Sound sensors capture and analyze equipment acoustic signatures, enabling detection of abnormal noises from bearings, gearboxes, and flow disturbances. Gas sensors monitor ambient atmospheric composition, temperature-humidity sensors track environmental conditions, and vibration sensors detect mechanical anomalies.
The robot travels on a suspended rail system with a maximum speed of 0.81 m/s, capable of navigating grades up to 35° and turns with a minimum radius of 2 meters. The PTZ camera provides 360° horizontal and 5°–90° vertical coverage, ensuring no inspection target is outside the viewing envelope. Positioning precision of ≤100 mm ensures that the robot stops at exactly the right location for each inspection point, and the 400-megapixel camera with 16× digital zoom provides the detail resolution needed for fine inspection tasks.
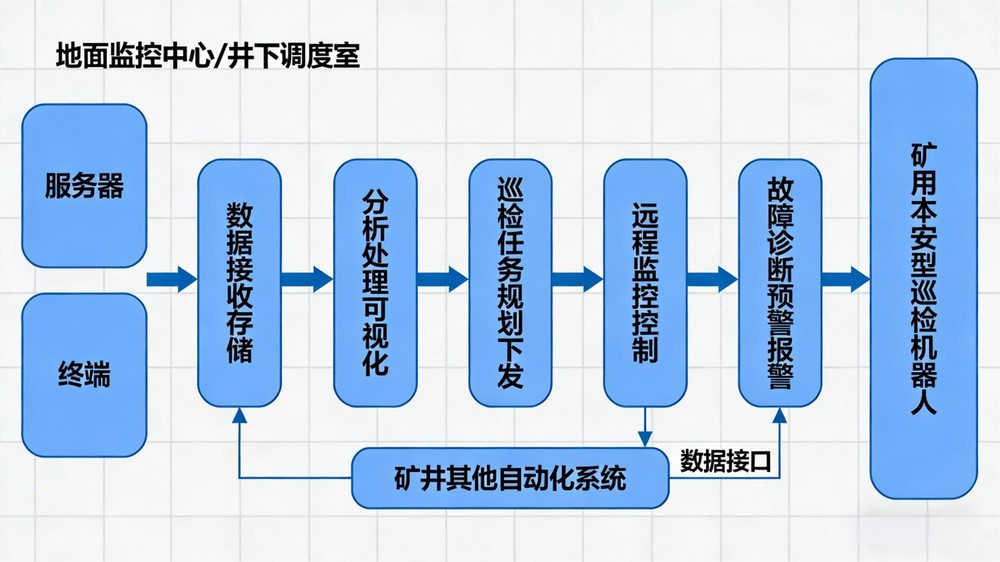
Autonomy is enabled by automatic return-to-charge functionality, ensuring continuous inspection capability without human intervention. The charging system uses a flameproof-and-IS charging pile at DC 48 V with a charging time of ≤2 hours at 10 A. The robot's battery provides a range of >10 km on level track at full charge. The dispatch platform software provides remote monitoring and control, enabling operators to configure inspection routes, review inspection data, and issue manual commands from a surface control center. The system's flameproof-and-IS construction allows deployment in Zone 1 explosive atmospheres, and it operates across a −20 °C to 60 °C temperature range with ≤95% relative humidity at +25 °C and IP54 protection.
Key Features
- Multi-sensor payload: HD camera, infrared thermal imager, sound, gas, temp/humidity, vibration
- All-weather unmanned inspection and monitoring
- Intelligent fault diagnosis with early warning and alarm
- Interoperability with other field equipment
- Automatic return-to-charge for continuous inspection
- Dispatch platform software for remote monitoring and control
- 400 MP camera, 16× digital zoom, 1080p@60fps, PTZ 360° horizontal
Technical Specifications
| Parameter | Value |
|---|
| Explosion Protection | Flameproof + IS |
| Dimensions | 900 mm × 500 mm × 600 mm |
| Weight | 90 kg |
| Travel Mechanism | Suspended rail |
| Climbing Angle | ≤35° |
| Turning Radius | ≥2 m |
| Speed | 0–0.81 m/s |
| Range | >10 km (level, full charge) |
| Operating Voltage | 48 V |
| PTZ Coverage | Horizontal 360°, vertical 5°–90° |
| Camera | 4 MP, 16× digital zoom, 1080p@60fps |
| Infrared Camera | 384×288, ±2°C/±2%, sensitivity 0.08 K, −20 °C to 150 °C |
| Charging Time | ≤2 h at 10 A |
| Charging Voltage | DC 48 V |
| Positioning Precision | ≤100 mm |
| Operating Temperature | −20 °C to 60 °C |
| Humidity | ≤95% (+25 °C) |
| Protection Rating | IP54 |
Applications
Mine substation, pump room, belt conveyor line, ventilation machine room, and other key equipment area inspection.
![]()
![]()
![]()